Application and project context
An anonymized Stellova service-robot battery project pairing a 48 V, 30 Ah LiFePO4 configuration with CAN communication and a project-specific enclosure.
Customer identity is withheld. This reference presents the specific battery configuration documented for the project, rather than a universal specification for every service robot.
Documented battery configuration
Interface and mechanical definition
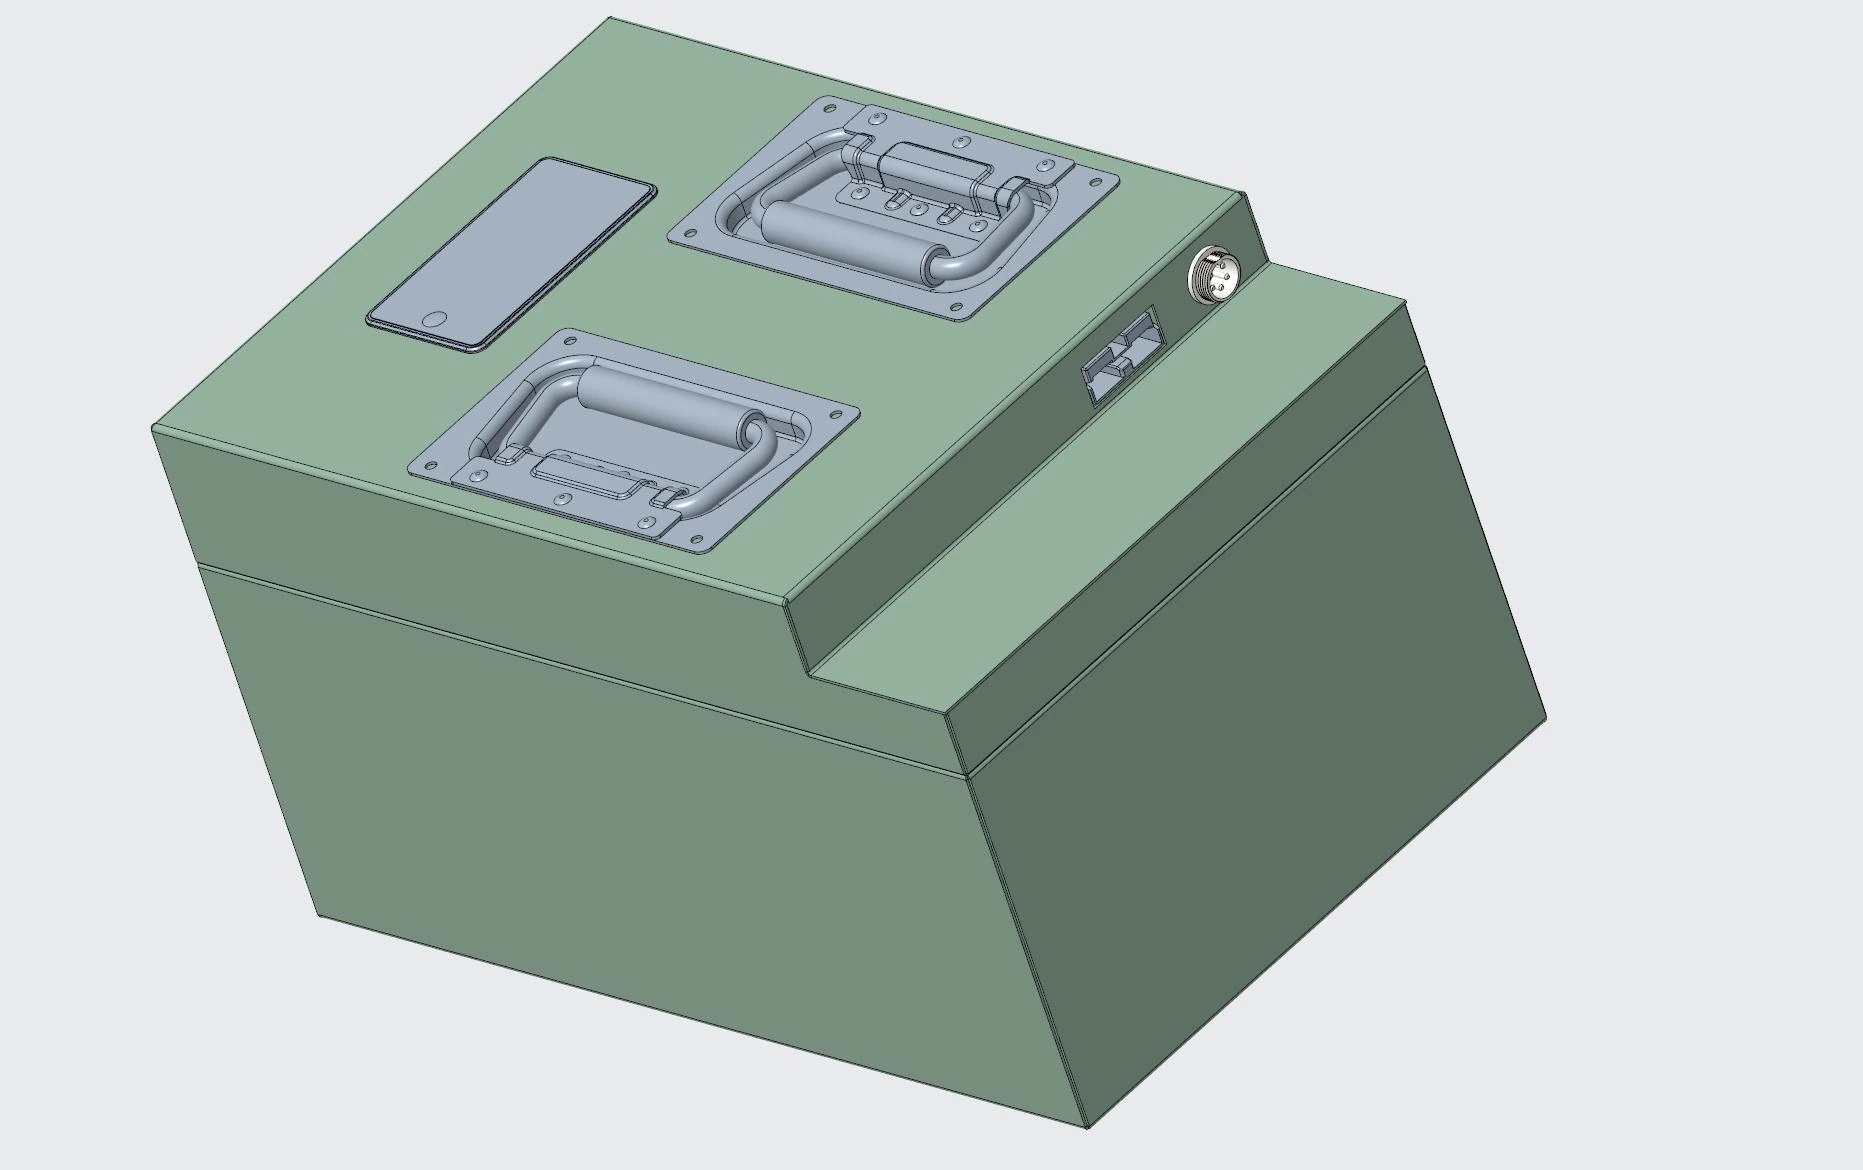
This project uses a CAN interface and a different enclosure from the RS485 configuration. The project drawing identifies the pack layout, handling features, communication connector and power connection as parts of one installation definition.
What this project illustrates
Matching nominal voltage and typical capacity does not establish a drop-in replacement. Communication, connector assignments, charger limits, mounting and the full mechanical envelope must also match the equipment requirements.
Runtime depends on the robot mission, drive and accessory loads, charging opportunities and operating reserve. The published capacity alone is not a runtime guarantee. Production and validation requirements are agreed for the target robot and charger.
Project Compliance and Transport Documentation
Documentation for these project references can include the following types of files. The documents actually issued depend on the battery configuration and destination market. Stellova can provide the applicable files under a confidentiality agreement (NDA); they are not available for public download:
- EU Battery Regulation CE Declaration of Conformity (CE DoC)
- RoHS documentation covering ten restricted substances
- CE EMC documentation
- REACH Annex XVII documentation
- FCC SDoC
- Material Safety Data Sheet (MSDS)
- UN38.3 documentation
- Dangerous goods packaging documentation
Discuss a related service-robot requirement
Share the load profile, charging arrangement, controller interface, installation space and target operating conditions.
Review service robot battery requirements · Smart battery packs and BMS · Discuss your project